Antigravitieee · 1st place, IEEE Montclair Micromouse Competition 2026
Justin Parra
Electrical and computer engineering at Rutgers. I design the boards, write the firmware and tune the robots.
Take it apartAntigravitieee
Ten parts, one maze-solver. Pick any part to watch it spin and read the code that runs it.
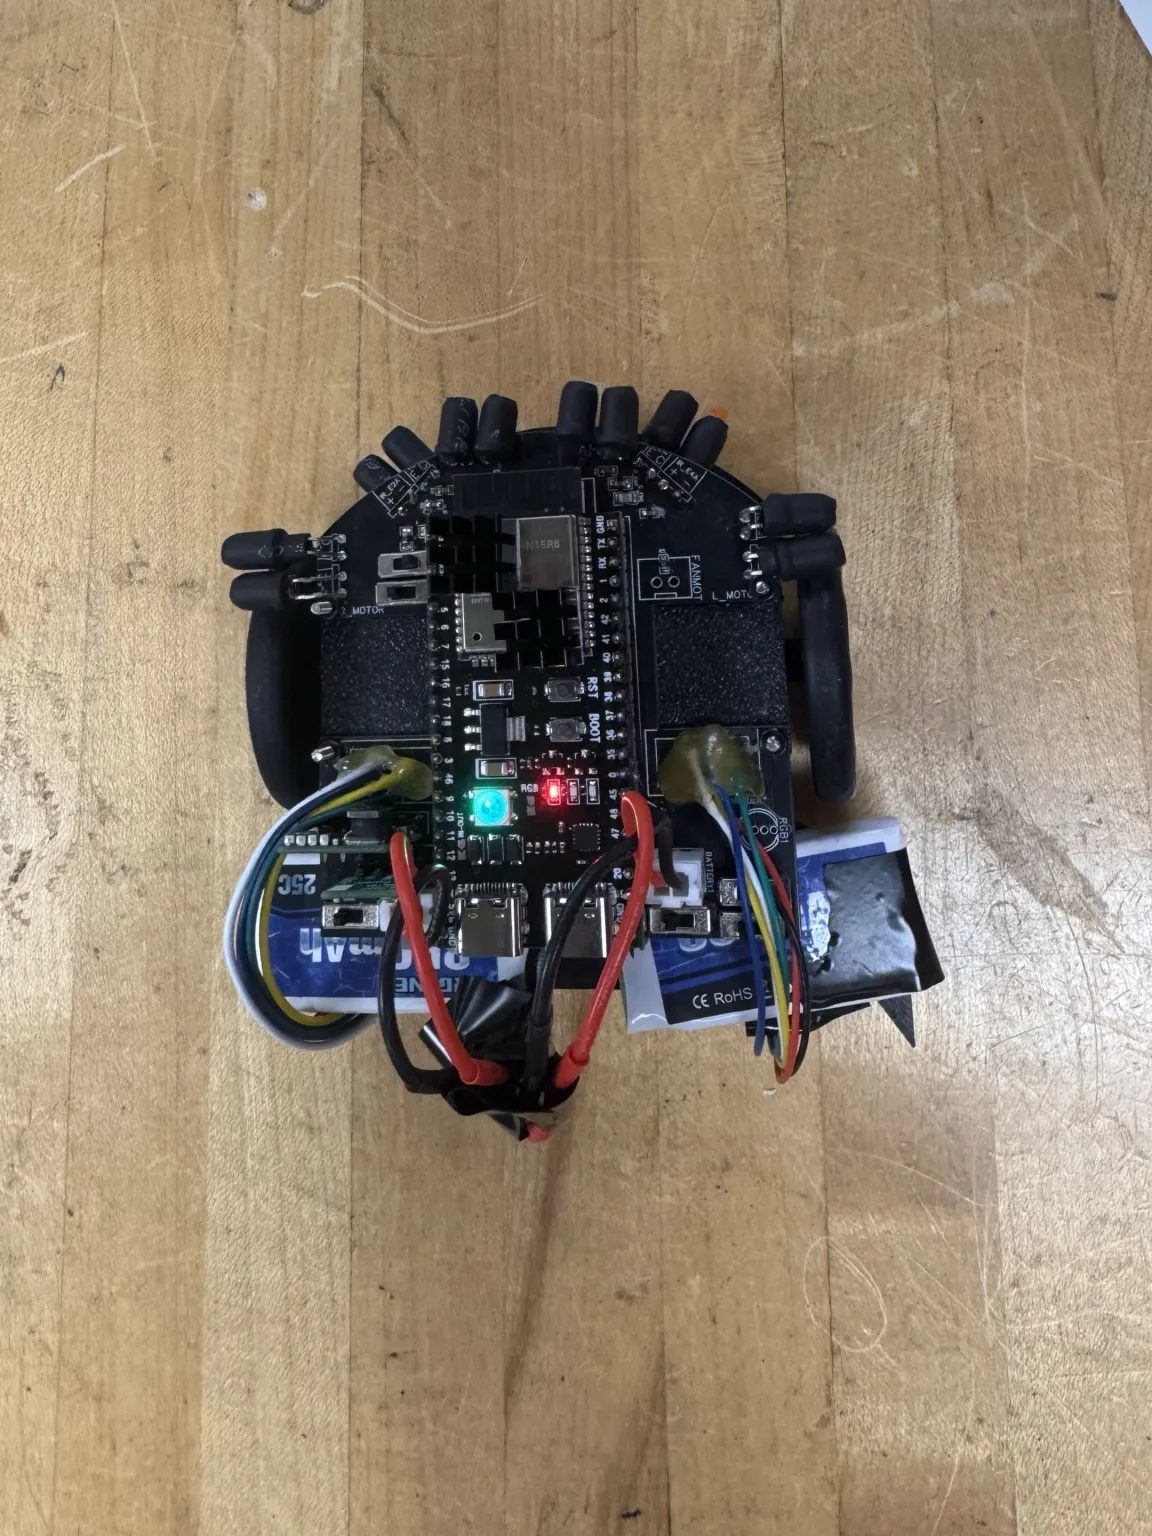
PCB and base plate from our own EasyEDA and print files. Motors and modules drawn to their datasheet sizes.
First place
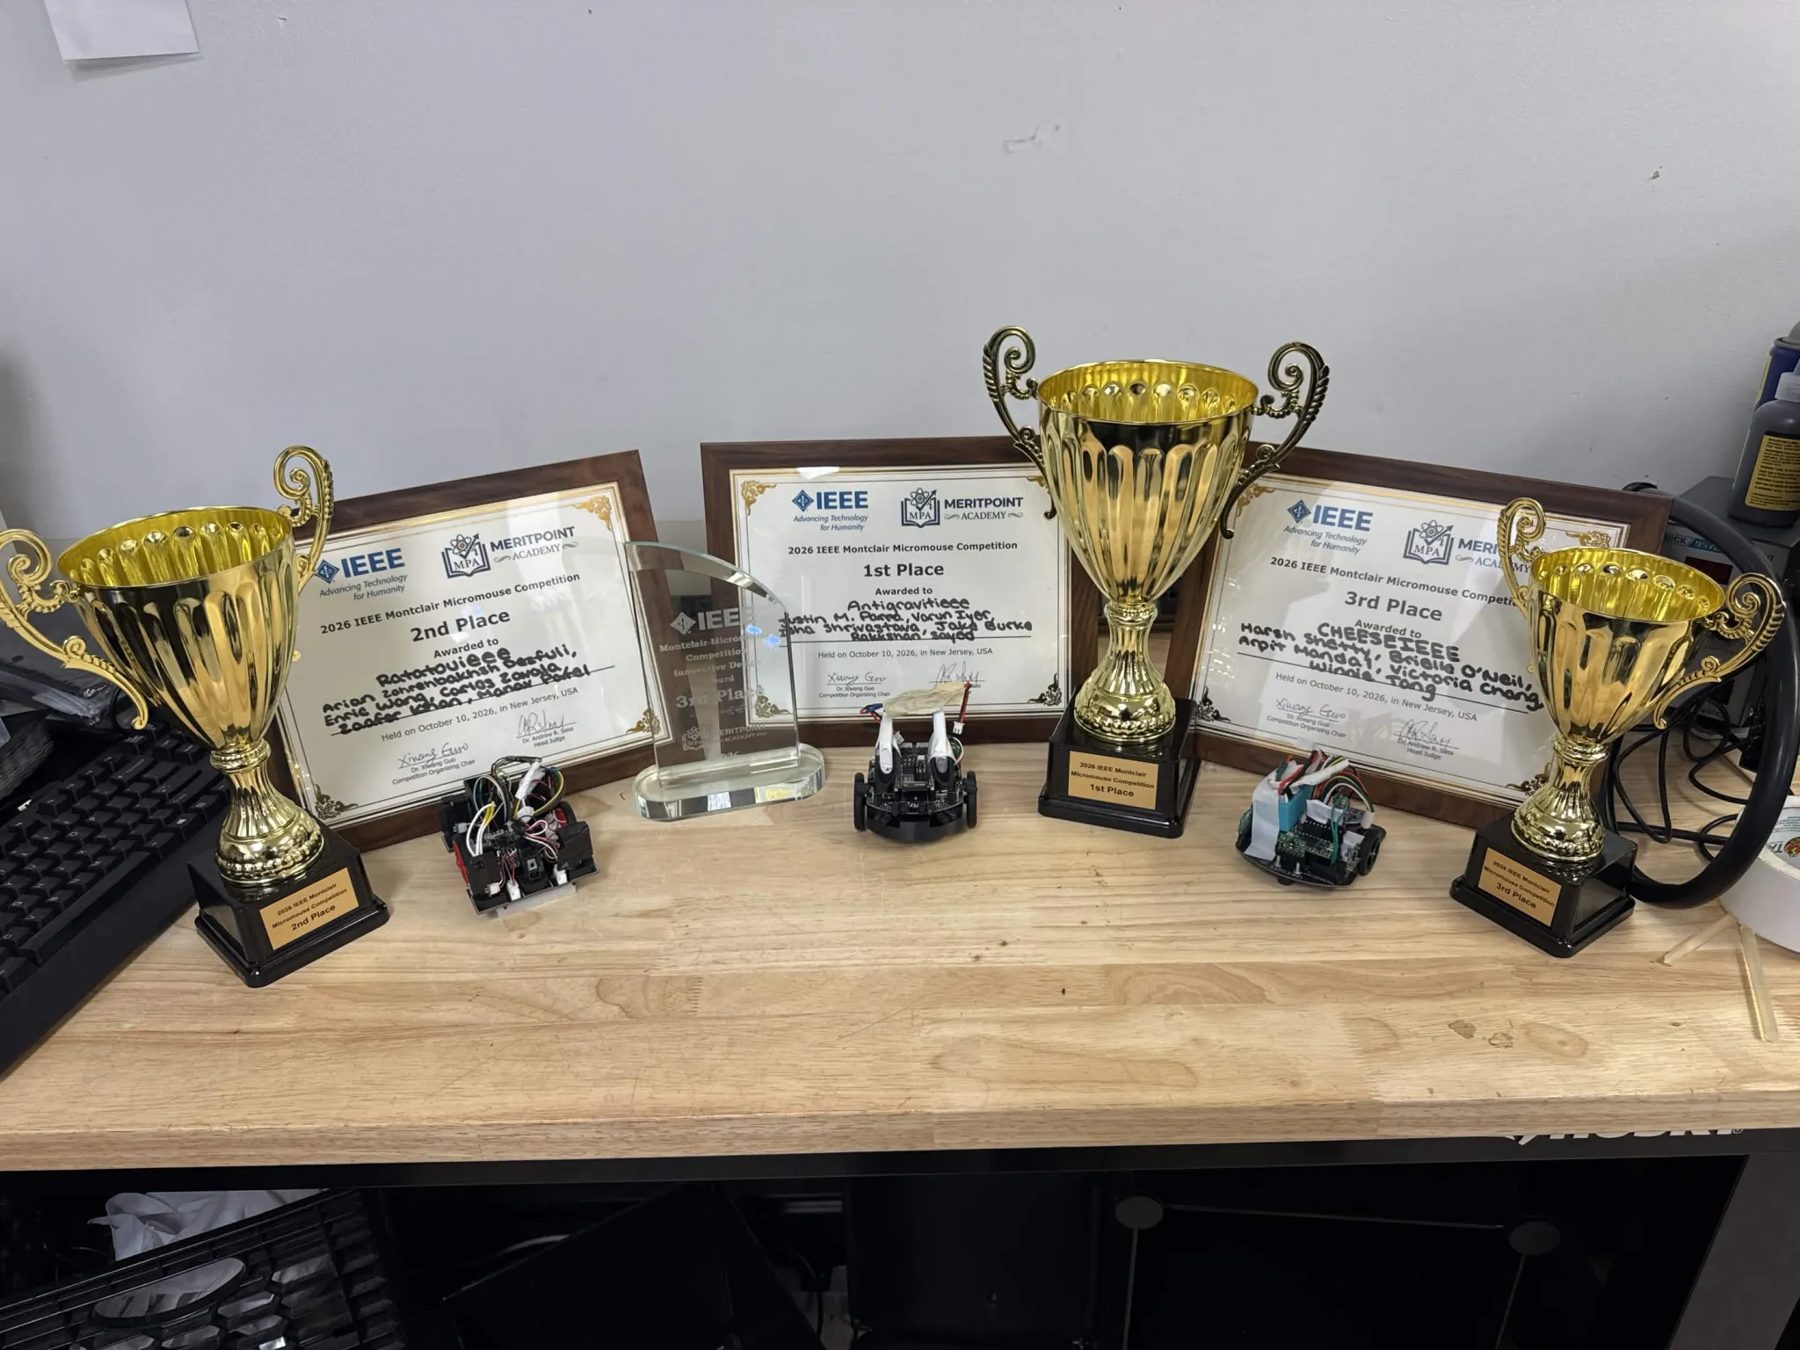
2026 IEEE Montclair Micromouse Competition, October 10. Rutgers teams took first, second and third; Antigravitieee is the first-place certificate.
Search
The first run maps the maze one cell at a time with flood fill, re-planning at every wall the IR sensors find.
500 Hz motion loop on its own core
Speed run
The second run plans the fastest path with Dijkstra over the saved map, cutting diagonals and chaining smooth curves instead of stopping at corners.
167 reads per second, per IR sensor
Holding the middle
The side sensors and the steering loop, running the robot's own numbers. Push it toward a wall.
Work
About
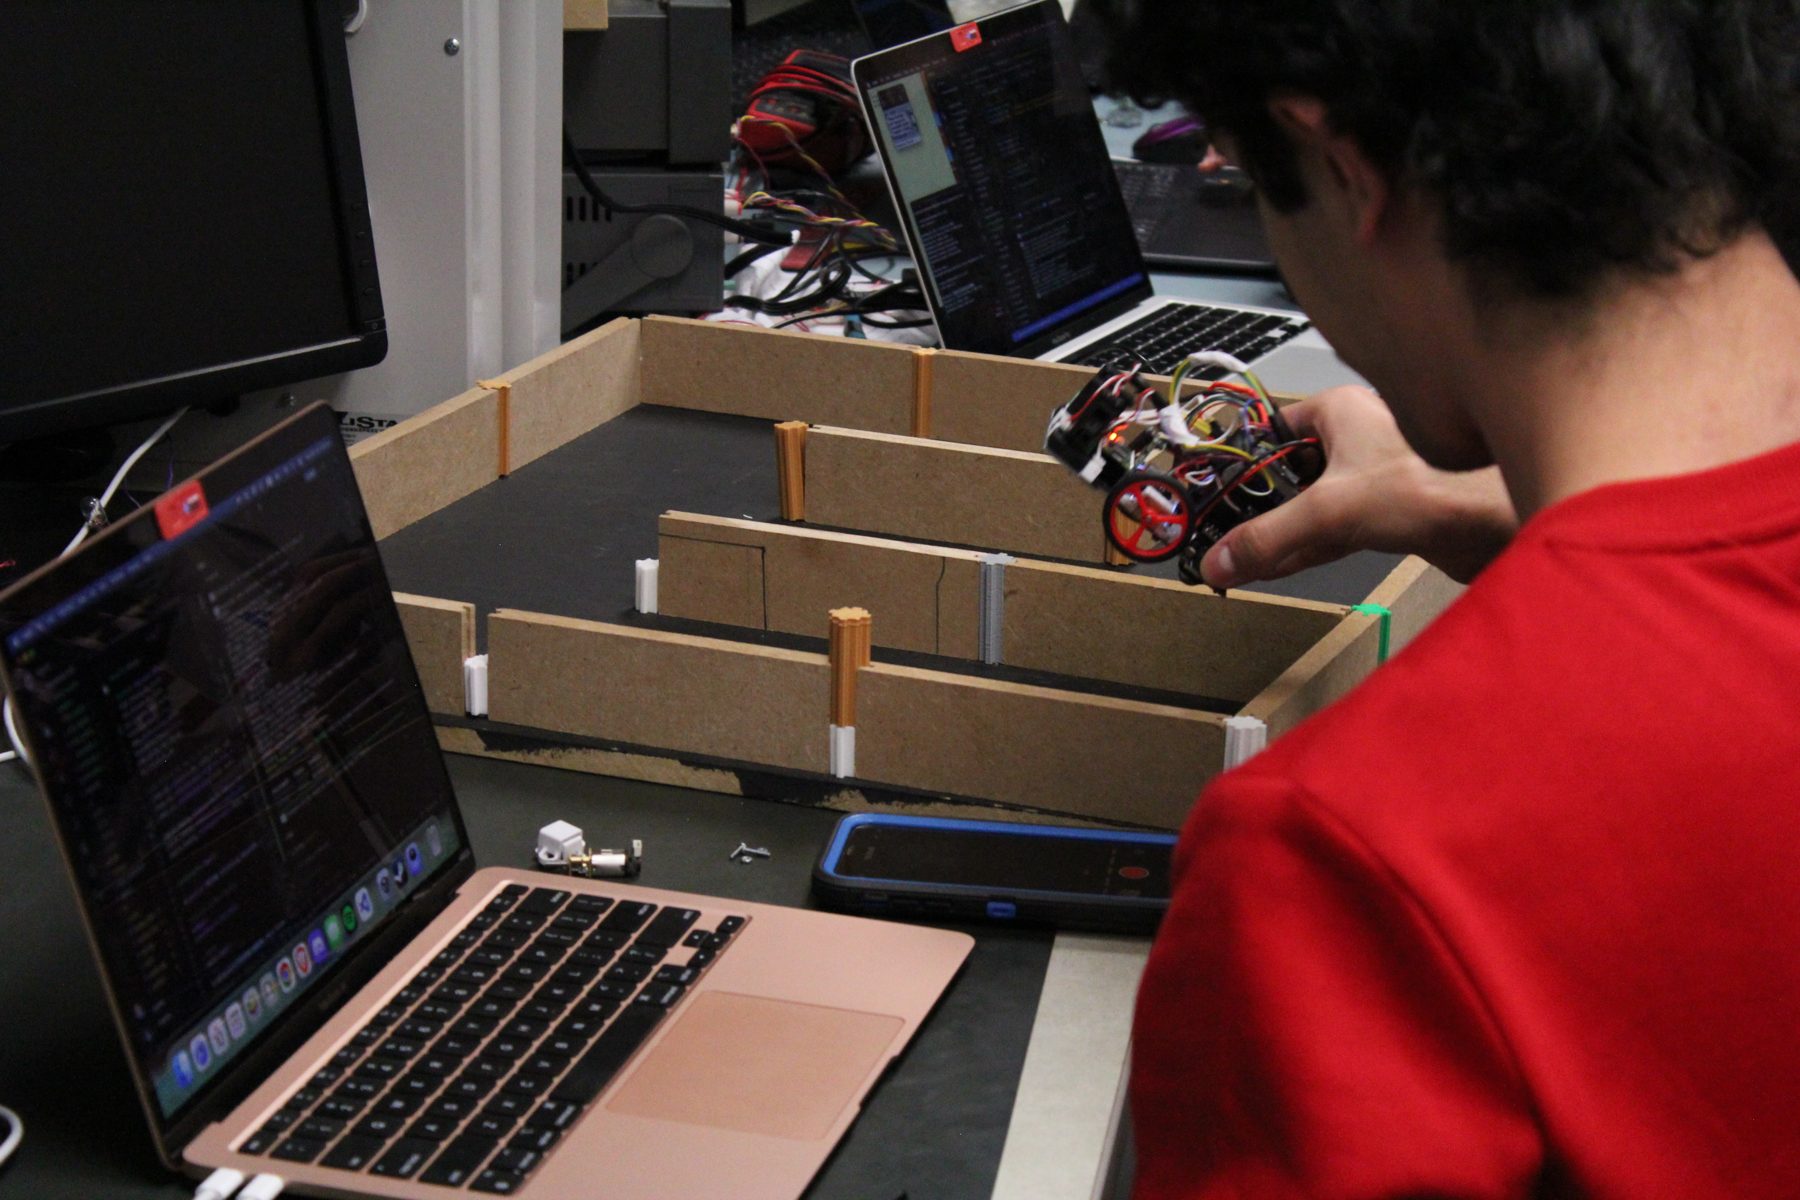
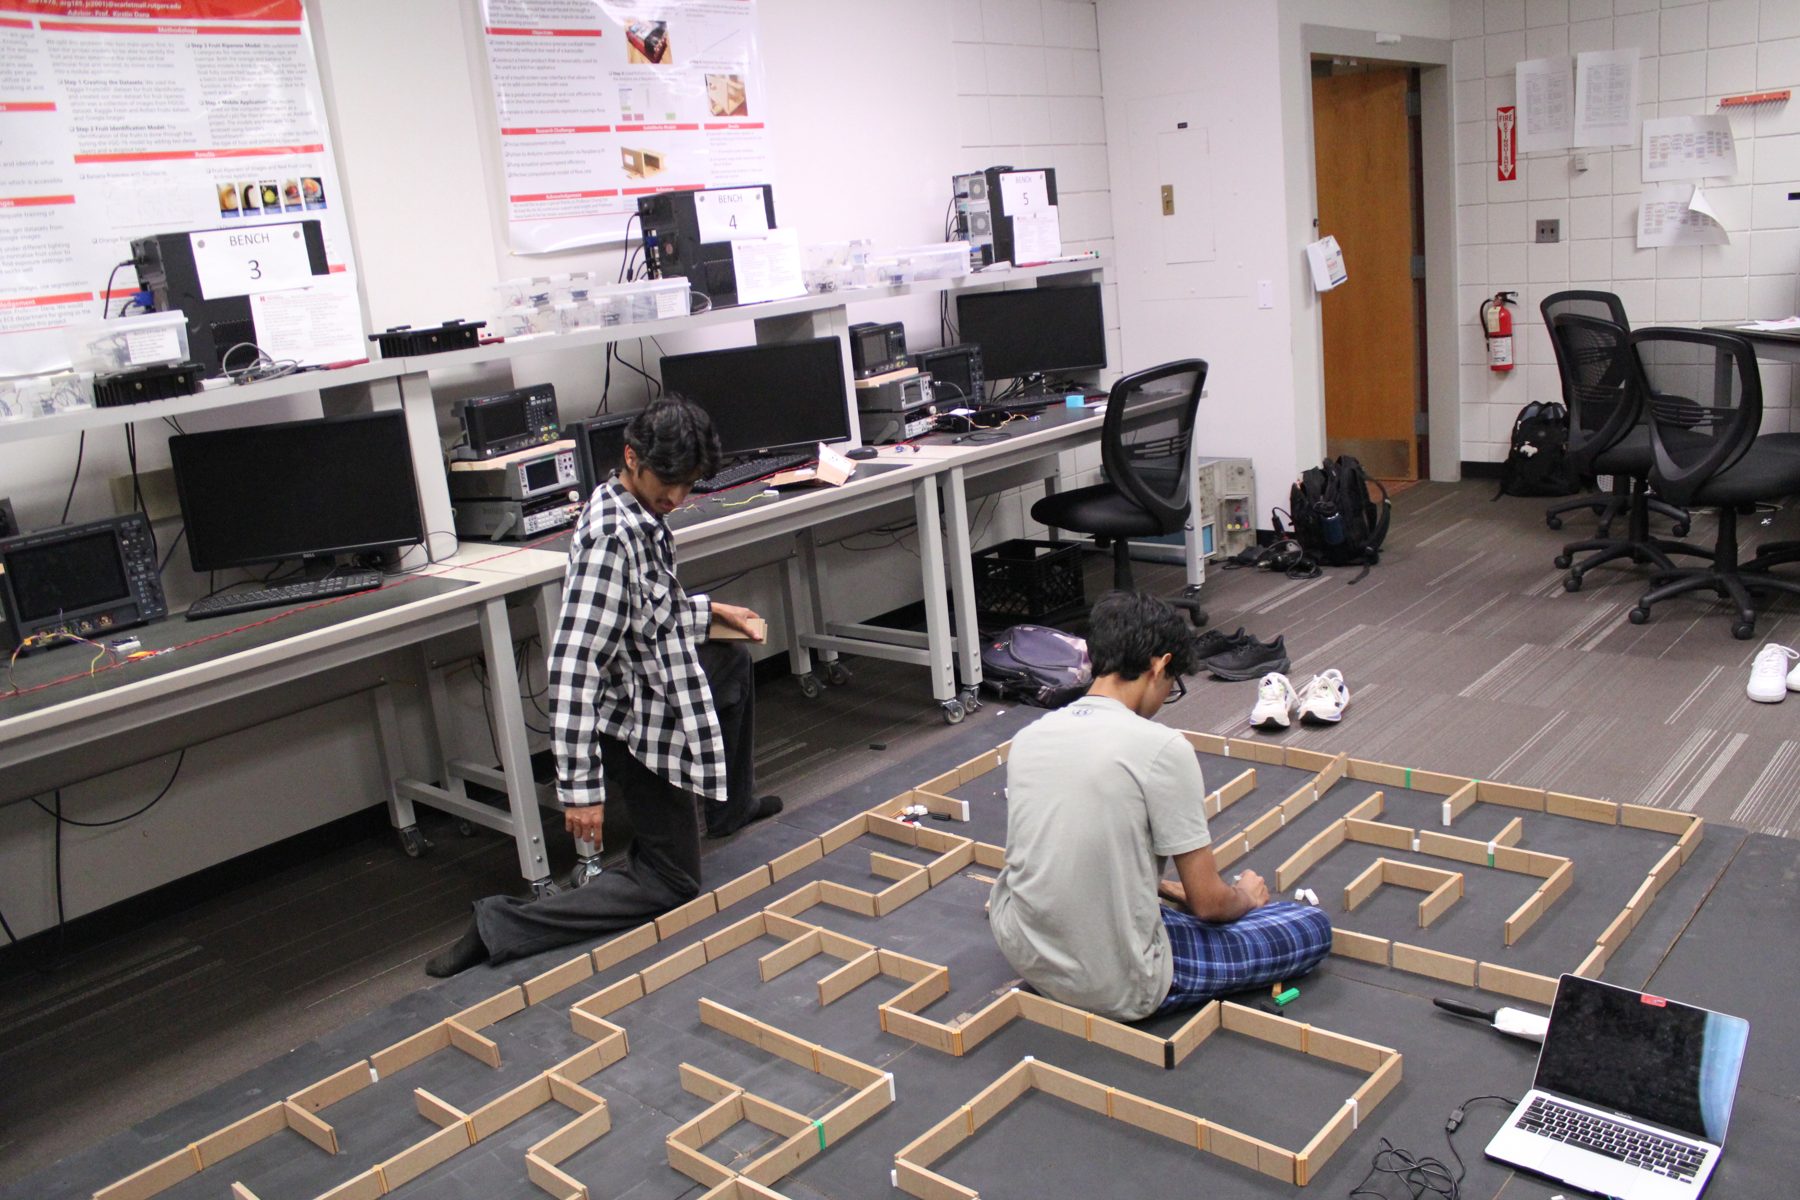
I'm the president of Rutgers Micromouse, where 40-plus students build robots that solve mazes on their own. I design boards in KiCad, Altium and EasyEDA, write C and C++ for ESP32-S3 and STM32, and tune control loops on the maze floor until the robot stops touching walls.
- Based in
- Dunellen, New Jersey
- Studying
- B.S. Electrical and Computer Engineering, Rutgers–New Brunswick, December 2027
- Speaks
- English and Spanish
- Looking for
- 2027 internships and co-ops, and new-grad roles in embedded, hardware and robotics
Experience
- President and lead firmware/hardware engineer, Rutgers Micromouse2024–now
- Electronics engineering lead, IEEE VEX division2024–now
- Engineering intern, LPT-KEYPAK2024
- Grew the team's active membership by 900%40+ members
- Corporate sponsorship raised for the team$2,500+
Honors
- 1st place, IEEE Montclair Micromouse Competition2026
- 2nd place, Rowan Regional Micromouse Competition2025
- Selected competitor, StarkHacks at Purdue2026
- Packaging throughput raised at LPT-KEYPAK+30%
- Equipment-related defects cut at LPT-KEYPAK−15%
Tools
- C, C++, Python, TypeScript, MATLAB, VerilogCode
- ESP32-S3, STM32, FreeRTOS, PlatformIOEmbedded
- KiCad, Altium Designer, EasyEDA, LTspiceBoards
- Oscilloscopes, logic analyzers, SMD reworkBench
- PID and cascade PID, flood fill, A*, DijkstraControl
Let's build something
Hiring for embedded, hardware or robotics? Write to me.
jstnp18@gmail.com